Back
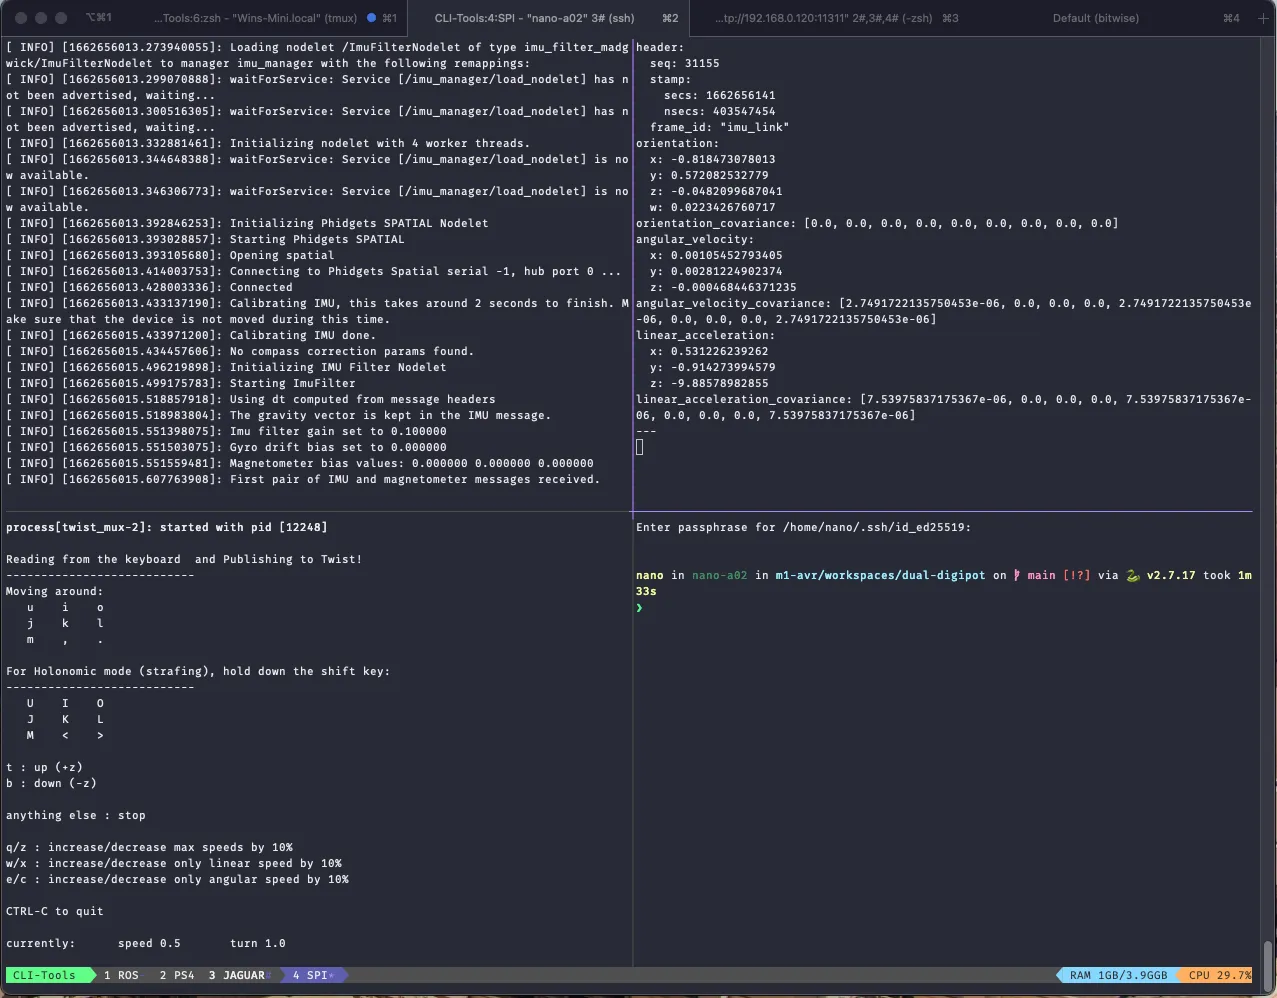
Bring up board 1044 over Noetic through the phidgets_drivers wrapper, then calibrate the compass so the heading means something
ros
imu
development